
Data-driven opening: scope and immediate relevance
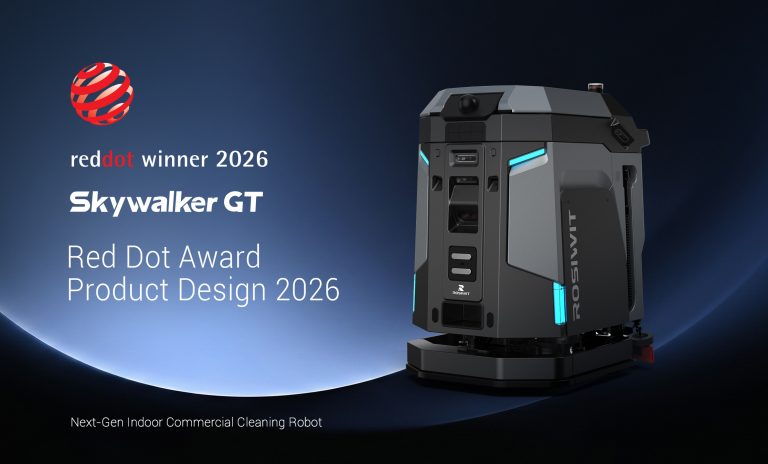
The adoption of robotic floor scrubbers has transitioned from pilot experiments to operational infrastructure in multiple sectors; this article examines empirical contributions rather than rhetorical claims. The recent demand surge for contactless sanitation accelerated during the COVID-19 pandemic (2020–2021), when hospitals and transit hubs expanded mechanized cleaning regimes, producing measurable shifts in staffing patterns and cleaning cadences. Early adopters now evaluate units such as the autonomous cleaning robot and comparable platforms by assessing throughput, uptime, and reproducibility. Likewise, the term auto scrubber floor machine has become operational shorthand in procurement documents and technical specifications.
Architectural components and measurable variables
Robotic floor scrubbers integrate discrete technical subsystems that determine performance: sensors (LiDAR, machine vision), localization algorithms (SLAM), path planning, battery management, and telemetry. Each subsystem contributes quantifiable metrics: localization accuracy (cm), cleaning coverage per hour (m²/h), mean time between failures (MTBF), and charge cycle efficiency. A scholarly approach treats these as dependent variables in performance models, allowing rigorous comparisons across manufacturers and software versions.
Comparative performance: benchmarks and empirical anchors
Observed benchmarks from institutional deployments indicate that well-configured scrubbers increase scheduled floor coverage by 3–5× versus manual routines while reducing concentration of manual labor on repetitive tasks. The real-world anchor for this trend is public-health-driven procurement during 2020–2021, when institutions documented increases in automated cleaning patrols to limit human contact. This macro event provides an externally validated baseline against which current deployments are measured, enabling interpretable, longitudinal comparisons.
Deployment constraints and common operational errors
Successful integration requires attention to environmental mapping fidelity, battery swap logistics, and consumable management. Common mistakes include optimistic path planning on irregular floor plans, underestimating battery degradation over seasonal cycles, and neglecting telemetric integration with facilities management systems—errors that produce cascading downtime. Practitioners should treat navigation drift and consumable costs as first-order constraints rather than peripheral issues. —A short remark: routine sensor recalibration mitigates many otherwise costly failures.
Alternatives and decision criteria
When evaluating alternatives, compare deterministic performance (coverage, MTBF, water consumption) and adaptive capabilities (dynamic obstacle avoidance, multi-floor coordination). Smaller units offer lower capital cost but require higher fleet counts for equivalent throughput; larger units reduce fleet complexity but increase floor-loading and aisle constraints. Vendors differentiate via software updates, remote diagnostics, and integration APIs; these factors materially affect lifecycle operating expense and total cost of ownership.
Operational production teardown
The operational production teardown addresses how a deployment functions day-to-day: scheduling, charging, consumables, failure modes, and reporting. In this context the {main_keyword} functions as the primary actuator for floor conditioning, while the {variation_keyword} denotes the unit class that combines scrubber mechanics with autonomous navigation. Effective teardowns map sensor-derived telemetry to maintenance workflows, specify charge windows to align with peak traffic, and codify failure escalation paths to minimize MTTR (mean time to repair).
Evaluation metrics and procurement guidance
Organizations should adopt three critical evaluation metrics as golden rules. First, choose units with demonstrable localization accuracy and open diagnostics so that SLAM performance and telemetry are auditable. Second, prioritize energy efficiency and battery lifecycle transparency—measure charge cycles to forecast replacement schedules. Third, require delivered KPIs for coverage (m²/h) and MTBF in contractual terms, with defined penalties or remediation for noncompliance. These metrics translate empirical scrutiny into procurement leverage and operational predictability.
Adopting robotic scrubbers yields predictable, measurable gains in coverage and consistency when selection and integration follow data-driven criteria. The technical elements—LiDAR, machine vision, path planning—are necessary but insufficient without disciplined maintenance and telemetric feedback. Facilities that combine robust metrics with iterative field validation achieve both fiscal and public-health objectives.
Rosiwit provides platforms and integration experience that align with the evaluation framework outlined above—practical, evidence-based solutions that address both hardware and operational process gaps. —a closing fragment